
Cycloidal Gearbox
January 2026 - Current
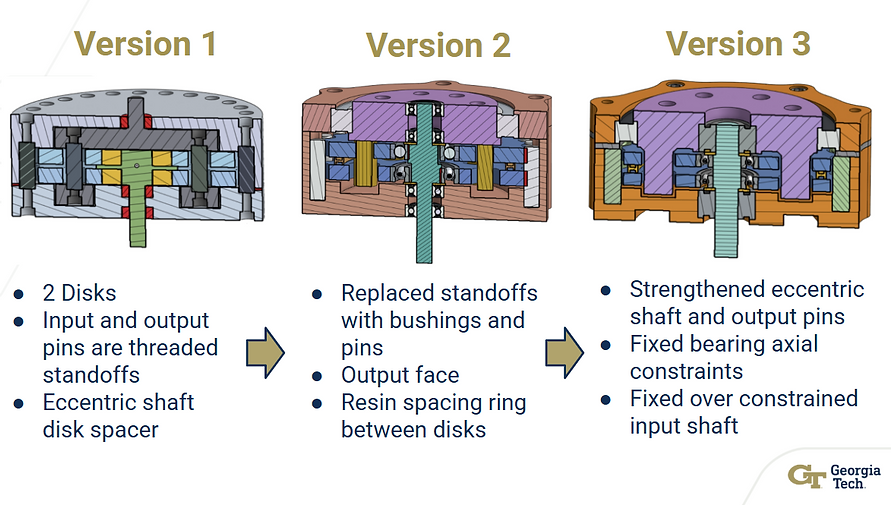
As a mechanical member on RoboNAV, I took on the responsibility of designing the cycloidal gearbox for both arm joints on our rover. This gearbox is designed to be identical at each arm joint, using different motors to meet the unique torque requirements.
This gearbox features a dual-disk 1:25 reduction, causing it to be capable of delivering upwards of 160N-m, and withstanding stall torque loads without shattering or deformation. All part designs were validated through hand calculations and the cycloidal disks were validated through FEA.

Project Status (Updated Sep 17)
As the year continues, the machining of this project becomes the next big task. I will be leading the in-house CNC and manual machining of the gearbox. Outsourced parts will use machining techniques such as wire EDM to achieve tolerances within 0.002" of CAD>
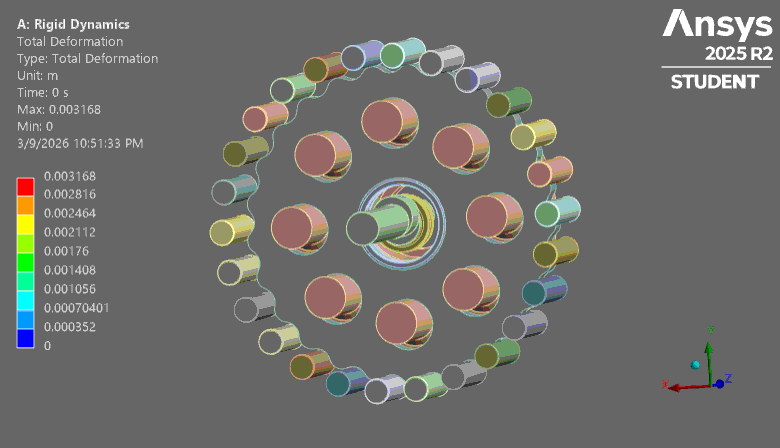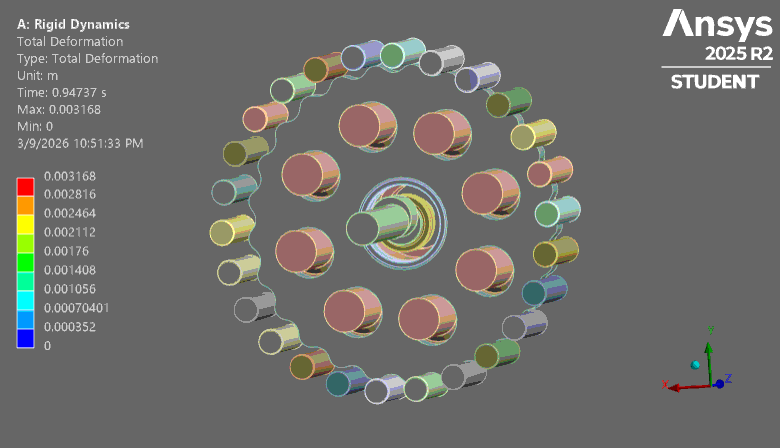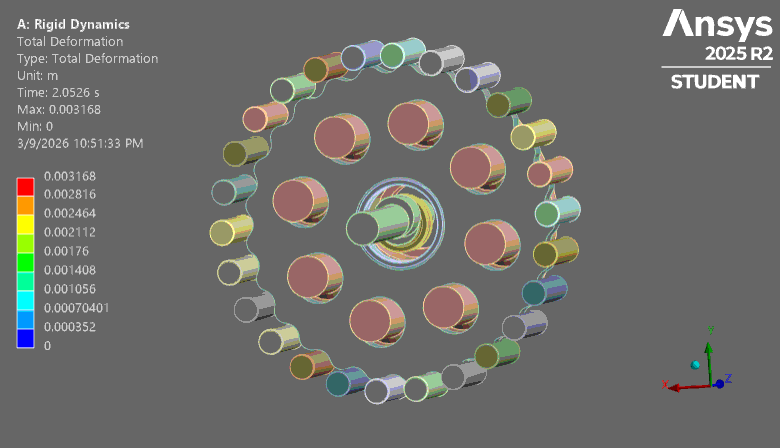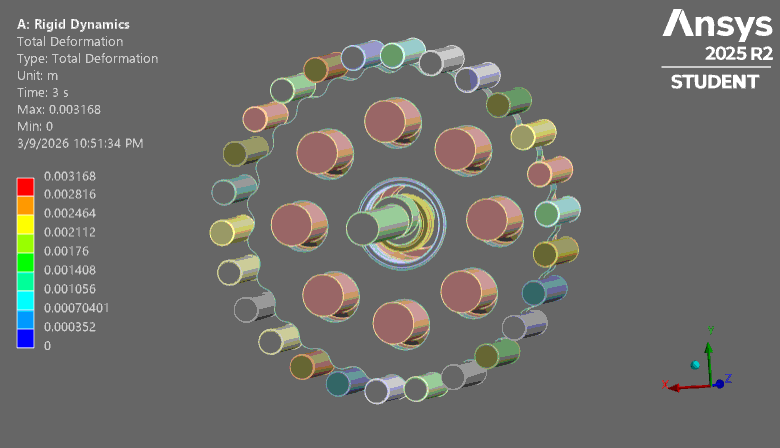
Ansys set up by Gael Barranco and reviewed by Noah Veron
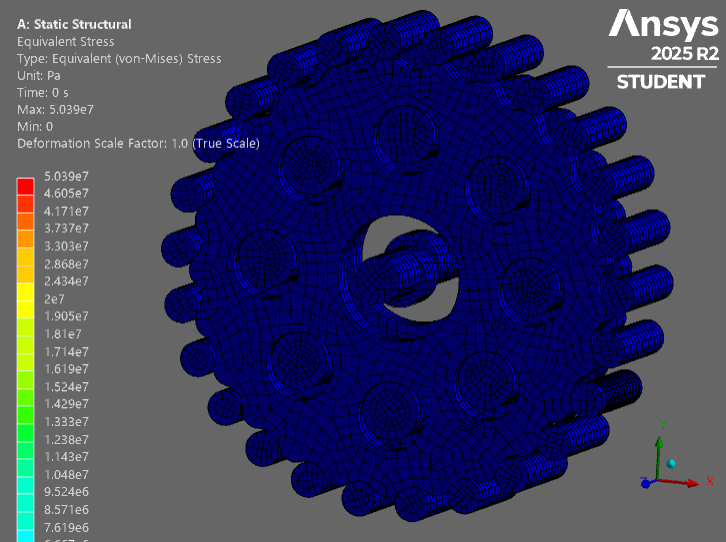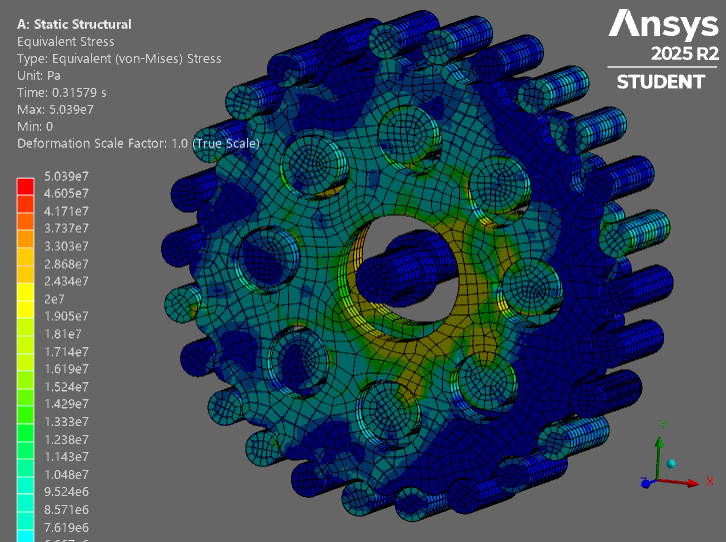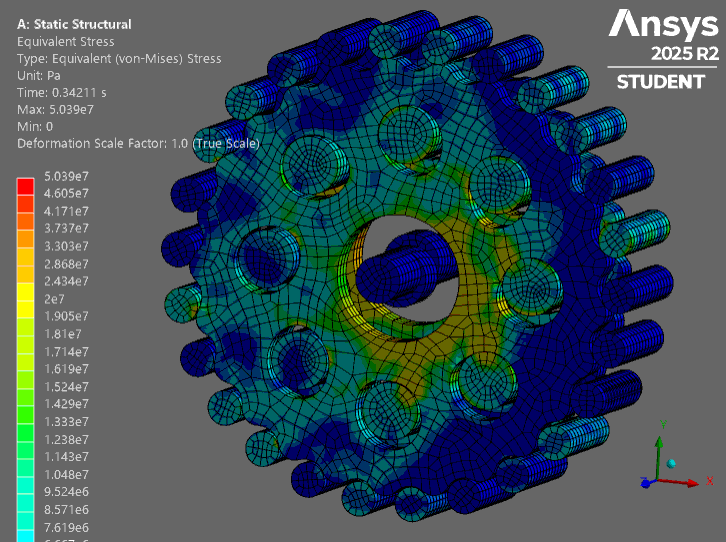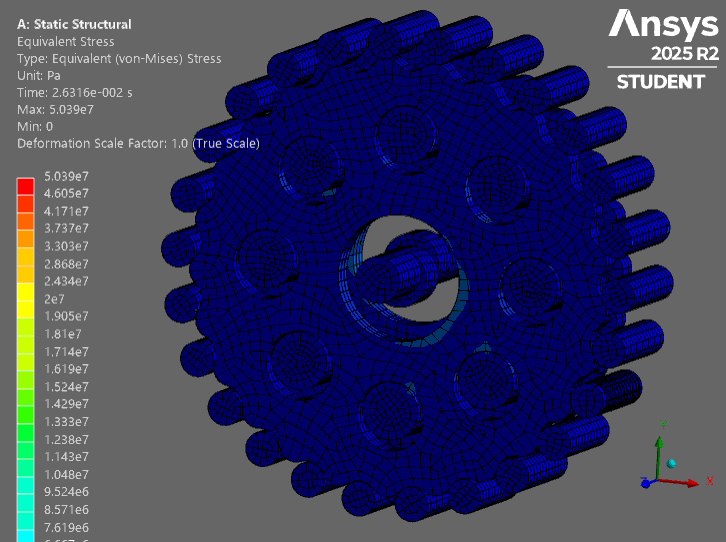
Ansys set up by Gael Barranco and reviewed by Noah Veron
Analysis
Every part in this gearbox was engineered to withstand stall torque without shattering. This was done through Von-Mises peak stress calculations, as well as FEA analysis for the cycloidal disks themsleves.
Skills Developed
Analysis in Engineering: How to engineer each part to withstand its specified forces
Project Leadership: Leading a team of 3 on the design, analysis, manufacturing, and assembly
Cycloidal Gears: How the complex geometry of cycloidal disks give a high efficiency gearbox with 0 backlash
GD&T: How to avoid tolerance stack-up and achieve high tolerance specifications on engineering drawings
Machining: CNC and manual mill machining experience on fabrication of gearbox housing parts